Kia Picanto: Forward Collision-Avoidance Assist malfunction and limitations / Limitations of Forward Collision-Avoidance Assist
Forward Collision-Avoidance Assist in the Kia Picanto depends on the detecting sensors being able to recognise the road ahead correctly. Under the following circumstances, the system may not operate as expected, may provide no assistance or may intervene unnecessarily:
-
The detecting sensor or the area around it is contaminated, obstructed or damaged.
-
Environmental conditions cause the temperature around the front view camera to become excessively high or low.
-
The camera’s view is affected by windscreen tinting, film or coating, damaged glass, or material stuck to the glass, such as a sticker or an insect.
-
Moisture has not been cleared from the windscreen, or water has frozen onto the glass.
-
Washer fluid is being sprayed continuously, or the windscreen wipers are operating.
-
The vehicle is travelling through heavy rain, snow or dense fog.
-
Sun glare obstructs the front view camera’s field of vision.
-
Streetlights or the lights of approaching traffic reflect from wet road surfaces, including puddles.
-
An object has been placed on top of the instrument panel.
-
Your vehicle is being towed.
-
The surroundings are extremely bright or very dark, such as inside a tunnel.
-
Light levels change abruptly, for example when entering or leaving a tunnel.
-
Outside light levels are low and the headlights are switched off or do not provide sufficient illumination.
-
Only part of a vehicle, powered two-wheeler, pedestrian or cyclist is detected.
-
The vehicle ahead has a profile that is difficult to recognise, such as a bus, heavy truck, truck with an unusually shaped load or trailer.
-
The vehicle or powered two-wheeler ahead has no tail lights, or its tail lights are positioned unusually.
-
Ambient light is low and the tail lights of the road user ahead are switched off or too dim.
-
The rear of the vehicle ahead is small or does not present a normal outline, for example because the vehicle is tilted, overturned or positioned with its side facing you.
-
The vehicle ahead has unusually low or high ground clearance.
-
A vehicle, powered two-wheeler, pedestrian or cyclist suddenly moves into your path.
-
The bumper around the front radar has been struck or damaged, or the radar has moved out of its correct position.
-
The temperature around the front radar is excessively high or low.
-
You are driving through a tunnel or across an iron bridge.
-
You are travelling across an extensive open area with few vehicles or structures, such as a desert, meadow or sparsely developed suburban area.
-
You are driving near substantial metal structures or materials, such as those found at construction sites or railway lines.
-
A nearby object, such as a guardrail or another vehicle, strongly reflects signals from the front radar.
-
A cyclist ahead is riding a bicycle made from materials that do not reflect the front radar’s signals effectively.
-
The vehicle or powered two-wheeler ahead is detected later than expected.
-
An obstacle suddenly blocks the sensors’ view of the vehicle or powered two-wheeler ahead.
-
The vehicle or powered two-wheeler ahead changes lanes abruptly or suddenly slows down.
-
The vehicle or powered two-wheeler ahead is damaged or distorted in shape.
-
Snow covers the vehicle ahead and obscures its normal outline.
-
Your vehicle is leaving its lane or returning to it.
-
The vehicle is moving unstably or being driven erratically.
-
You are travelling around a roundabout and the vehicle or powered two-wheeler ahead is not detected.
-
You continue driving in a circular path.
-
The vehicle or powered two-wheeler ahead has an unusual shape.
-
The vehicle or powered two-wheeler ahead is travelling uphill or downhill.
-
A pedestrian or cyclist is not fully recognised, for example because the person is leaning forwards or is not walking upright.
-
The illustration above shows the profiles that the front view camera and front radar are capable of identifying as a vehicle, powered two-wheeler, pedestrian or cyclist. Recognition can be affected when the visible shape differs from these profiles.
-
A pedestrian or cyclist wears clothing or equipment that makes their outline difficult to recognise.
-
The pedestrian or cyclist ahead is moving very quickly.
-
The pedestrian or cyclist ahead is short or is in a low posture.
-
The pedestrian or cyclist ahead has limited mobility or is moving across your direction of travel.
-
A group of pedestrians, several cyclists or a large crowd is ahead of the vehicle.
-
A pedestrian’s or cyclist’s clothing blends into the background, making the person difficult to distinguish.
-
A pedestrian or cyclist is difficult to distinguish from a nearby structure with a similar shape.
-
You are passing pedestrians, cyclists, traffic signs or other structures near an intersection.
-
You are driving in any of the following environments, where detection may be affected:
-
Through steam, smoke or areas of shadow.
-
Through a tunnel or across an iron bridge.
-
Across large open areas containing few vehicles or structures, including deserts, meadows and sparsely developed suburbs.
-
Within a car park.
-
Through toll gates, construction areas or partly paved roads, or over uneven surfaces and speed bumps.
-
Near metal structures or materials in areas such as construction zones and railway surroundings.
-
On roads with gradients or curves.
-
Along roads bordered by trees or streetlights.
-
Along narrow roads with overgrown trees or grass.
-
Through areas where strong radio signals or electrical noise cause electromagnetic interference.
-
-
Poor road conditions cause excessive vibration while the vehicle is moving.
-
The vehicle sits lower or higher than normal because of heavy loads, incorrect tyre pressures or similar conditions.
-
Tyre chains, a spare tyre or a wheel of a different size have been fitted.
WARNING
-
Driving on a curved road
Curved roads can affect sensor performance and prevent Forward Collision-Avoidance Assist from detecting vehicles, powered two-wheelers, pedestrians or cyclists ahead. The system may consequently provide neither a warning nor braking assistance when they are needed.
Maintain a safe braking distance throughout the curve. Watch the road ahead, steer as necessary and press the brake pedal to reduce speed whenever you need more space from other road users.
On a bend, the system may also detect a vehicle, powered two-wheeler, pedestrian or cyclist in the neighbouring lane or outside your lane.
This can cause an unnecessary warning or braking intervention. Always monitor the traffic around your Kia Picanto and remain ready to control the vehicle yourself.
-
Driving on an inclined road
When travelling uphill or downhill, changes in the road gradient can affect the sensors’ view of vehicles, powered two-wheelers, pedestrians and cyclists ahead. The system may fail to recognise these road users correctly.
As a result, warnings or braking assistance may occur unnecessarily, or they may be absent when a collision risk requires a response.
If a vehicle, powered two-wheeler, pedestrian or cyclist suddenly becomes detectable, automatic braking may cause your vehicle’s speed to decrease rapidly.
Keep your attention on the road when climbing or descending. Steer appropriately and use the brake pedal whenever necessary to reduce speed and maintain a safe distance from traffic ahead.
-
Changing lanes
[A]: Your vehicle
[B]: Vehicle or powered two-wheeler changing lanes
[C]: Vehicle or powered two-wheeler in the same lane
When a vehicle or powered two-wheeler (B) moves into your lane, the sensor cannot detect it until it enters the sensor’s detection range. Its movement from an adjacent lane may therefore begin before the system recognises it.
Forward Collision-Avoidance Assist may not immediately detect a road user making an abrupt lane change. Leave sufficient braking distance, steer as required and apply the brake pedal to reduce speed if necessary. Do not wait for a warning before responding to a vehicle entering your path.
When a vehicle ahead (B) leaves your lane, another vehicle or powered two-wheeler (C) may become visible directly in front of you. The system may not recognise this newly exposed road user immediately. Maintain a safe gap and be ready to steer or brake to control your speed and preserve enough stopping distance.
-
Detecting a vehicle
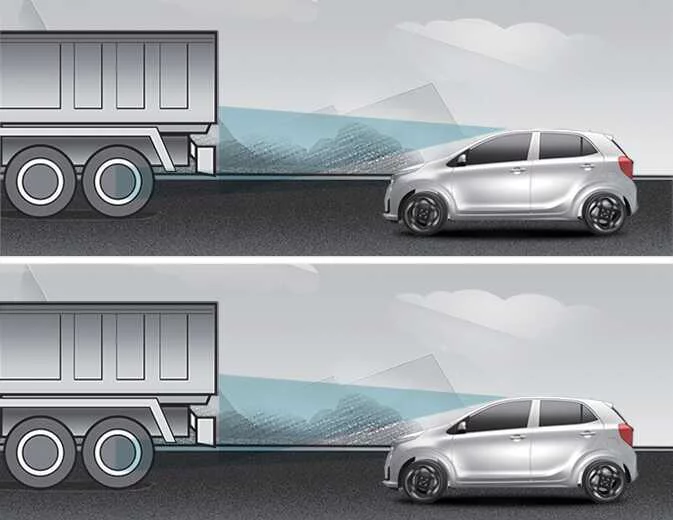
Use additional caution when following a vehicle with cargo extending behind its cab or with unusually high ground clearance. Forward Collision-Avoidance Assist may not detect the projecting cargo. Measure your safe following distance from the rearmost part of the load or vehicle, rather than from the cab alone. Steer as needed and apply the brakes to reduce speed whenever necessary to maintain that distance.
WARNING
-
For safety, Kia recommends switching off Forward Collision-Avoidance Assist when your Kia Picanto is towing a trailer or another vehicle.
-
Objects resembling vehicles, powered two-wheelers, pedestrians or cyclists in shape or other characteristics may cause the system to intervene, even when those objects are not the road users it is intended to detect.
-
Forward Collision-Avoidance Assist does not operate for carts, bicycles, suitcases, pushchairs or similar objects being pushed or pulled by pedestrians or cyclists. Do not rely on the system to respond to these objects.
-
Strong electromagnetic interference may disrupt Forward Collision-Avoidance Assist and prevent normal operation.
-
Forward Collision-Avoidance Assist may be unavailable for 15 seconds after the vehicle starts or the front view camera is initialised. Remain prepared to control the vehicle without its assistance during this period.
 Forward Collision-Avoidance Assist malfunction
A: Check Forward Safety system
If Forward Collision-Avoidance Assist is..
 Lane Keeping Assist (LKA): (if equipped)
When your Kia Picanto travels above the required operating speed, Lane Keeping Assist recognises lane markings or
road edges ahead. If the vehicle begins to leave its lane without a turn signal b..
Other information:
Ford Explorer 2020-2026 Owners Manual: Using Traffic Sign Recognition
Setting the System Speed Warning The system has a number of speed warning levels that you can set using the information display. See General Information. System Display The system can display two traffic signs in parallel. You can view the status at any time using the information display...
Ford Explorer 2020-2026 Service Manual: Description and Operation - Climate Control System - Component Location
I..
Categories
- Manuals Home
- 6th Generation Explorer Owners Manual
- 6th Generation Explorer Service Manual
- General Procedures - Transmission Fluid Drain and Refill
- General Procedures - Brake Service Mode Activation and Deactivation
- Driveline
- New on site
- Most important about car
Integrated Keyhead Transmitter (If Equipped)
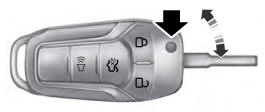
Use the key blade to start your vehicle and unlock or lock the driver door from outside your vehicle. The integrated keyhead transmitter functions as a programmed ignition key that operates all the locks and starts your vehicle, as well as a remote control.